
Zhong Lin Wang
Advanced Sensor and Energy Harvesting Materials
Brunel University of London
About
Research focus
Advanced Sensor and Energy Harvesting Materials
Impact
4,146 pubs · 442,261 cites · h-index 309
Affiliations
Publications
preclinical
OCT 16YangScience Advances
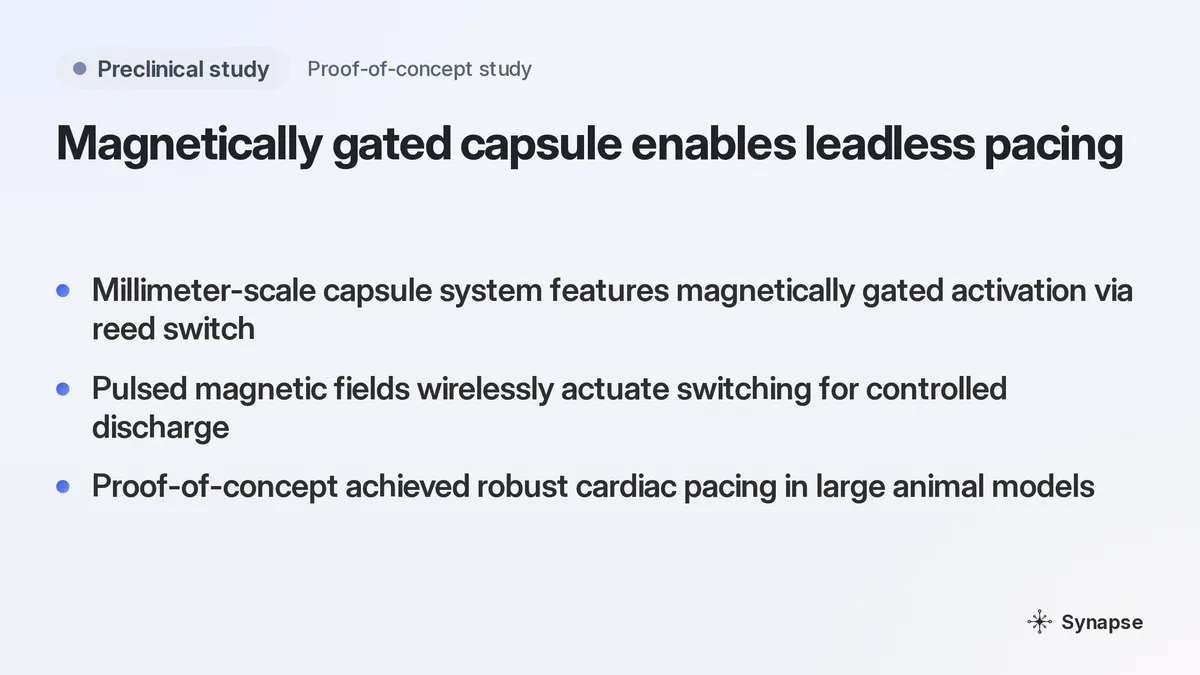
Magnetically gated millimeter-scale capsule power system enables robust temporary cardiac pacing in preclinical models.
A miniaturized, magnetically actuated reed switch capsule successfully enables wireless temporary cardiac pacing in large animal models, addressing limitations of existing temporary pacing systems.
Original Research
OCT 9ZhouAdvanced Functional Materials
Oceanic In Situ Power via Chaotic Multi‐Energy Harvesters
Wide‐area radiation and pollution affect the marine ecosystem and anthropogenic sustainability. A key implementation challenge is the lack of sustainable and on‐site power supply technology. Here, we propose a multi‐energy harvester integrated by wind‐wave dual‐driven triboelectric nanogenerators (WW ‐ TENGs) with the chaotic pendulum structure. The system was designed with multiphase flow optimization, simultaneously collecting wind and wave energy from the marine air‐sea interface. The peak power density of the device reaches 48 W/m 3 , with the energy conversion efficiency reaching 11.7%. Furthermore, we developed a marine radioactive monitoring system, which integrates in situ energy harvesting and powering and real‐time monitoring. In general, this work introduces a multiphase‐coupled energy harvesting and supply strategy, facilitating in‐depth research into the dynamic changes of marine ecosystems and advancing the early deployment of protection measures.
Original Research
OCT 7DuAdvanced Intelligent Systems
Topological Dielectric Fiber Networks for Self‐Powered Teleperception
Noncontact sensing is indispensable for intelligent human–machine interaction (HMI), autonomous robotics, and distributed Internet of Things (IoTs). However, the sensing range of existing triboelectric sensors remains fundamentally constrained because dense dielectric architectures limit charge trapping and dielectric polarization. Here, we develop a self‐powered triboelectric teleperception sensor (TTS) based on an electrospun poly(vinylidene fluoride)/barium titanate (PVDF/BTO) topological dielectric fiber network. COMSOL simulations, together with experimental characterizations, reveal that the three‐dimensional porous topology synergistically enhances charge trapping, electrostatic confinement, and dielectric polarization, while BTO nanoparticles further amplify the interfacial electrostatic field through enhanced dielectric response. These synergistic effects establish an efficient electrostatic induction mechanism for teleperception. Consequently, the TTS achieves a maximum sensing distance of 1.1 m, enables reliable discrimination of target materials and motion frequencies, and supports remote interaction with a robotic arm. Furthermore, a one‐dimensional convolutional neural network (1D‐CNN) enables intelligent recognition of approaching, receding, waving, walking, and running behaviors with an accuracy of 91.67%. By engineering dielectric topology to regulate electrostatic field coupling, this work establishes a general design strategy for self‐powered teleperception, providing a versatile sensing platform for intelligent robotics, HMI, and next‐generation embodied systems.
Original Research
OCT 7WangAdvanced Materials
Simultaneous Laser Light and Electromagnetic Wave Pulsed Emissions Triggered by Spatiotemporally‐Compressed Triboelectricity
Serving as information carriers, laser light (LL) and electromagnetic waves (EWs) lay the foundation of information sensing and communication systems for modern society, featuring different advantages and disadvantages. Simultaneously emitting LL and EWs with environmental information modulated in a self‐powered manner has great potential to benefit diverse applications, especially internet of things (IoTs). In this work, a triboelectricity‐driven radiator is developed for simultaneous emissions of LL and EWs. Driven by the environmental motion‐induced triboelectricity, the LL and EW emissions are achieved by the breakdown‐induced discharging via a tailored instantaneous charge transfer channel where the spatially accumulated charge is released within an ultrashort time. At least 5 environmental factors, including environmental motion profiles, concentrations of pollutants, gas components, liquid types, and the presence of metal, can be sensed and wirelessly transmitted. The information interaction can be operated in two modes, isotropic EWs and collimated LL. Attributed to the spatiotemporally‐compressed triboelectric mechanism, the generated ultrahigh current of 11 A drives the simultaneous LL and EW radiations for multidimensional sensing, achieving a highly competitive Figure‐of‐Merit of 100. Our results demonstrate a proof‐of‐concept of the all‐in‐one information system enabled by the TENG, paving a new avenue to achieve TENG‐based multiple‐environmental‐factor sensing.
Original Research
SEP 28YuAdvanced Functional Materials
Bio‐Inspired Flex‐Rigid Design Enabling High‐Performance Multimodal Locomotion of Robots
Biological locomotion often benefits from flex‐rigid architectures, where soft tissues coordinate with rigid skeletons or appendages to enable effective force transmission, versatile motion generation, and environmental adaptability. However, translating this paradigm to robotics remains challenging. Here, we present a bio‐inspired flex‐rigid robot (Bio‐FRR) that integrates a muscle‐like pneumatic actuating unit with a fin‐like rigid arched plate to achieve high‐performance multimodal locomotion. Unlike conventional rigid‐flexible hybrid robots in which rigid elements mainly serve as passive reinforcements or fixed appendages, the Bio‐FRR employs a deployable flex‐rigid mechanism, where a multi‐chamber pneumatic actuator actively drives rigid arched plates to fold and unfold, thereby converting local soft deformation into body‐level posture reconfiguration and locomotion‐relevant mechanical output. Such a design endows the Bio‐FRR with versatile and adaptive locomotion across various environments, realizing five high‐performance locomotion modes on land and in water without structural reconfiguration, including upright hopping, leapfrogging, terrestrial crawling, diving, and swimming. The Bio‐FRR reaches a maximum terrestrial speed of 1.23 body lengths per second (BL/s), a horizontal swimming speed of 0.42 BL/s, and an untethered driving speed of 48.67 mm/s. Bio‐FRR offers a robust blueprint for next‐generation amphibious soft robots, enabling versatile locomotion and enhanced adaptability.
Original Research
SEP 29GaoNature Communications
Multi-Stage buck strategy for power management of triboelectric nanogenerators
Triboelectric nanogenerators (TENGs) offer transformative potential for self-powered systems, yet their real-world applicability faces a key bottleneck as their performance and efficiency suffer dramatic degradation below 5 V that the operational threshold for most electronics when integrated with conventional power management circuits. Here, we overcome this limitation through the multi-stage buck strategy that synergistically combines dual-stage voltage conversion circuit with TENG’s output characteristic by the Q-V curve, enabling precise voltage regulation at critical nodes. The strategy achieves approximately 80% circuit efficiency at the low-voltage range, with 90.9% in the primary circuit and 93.9% in the secondary circuit. Concurrently, the current and power density reach 5.19 A/m 2 and 9.70 W/m 2 at 1.87 V, which is nearly an order of magnitude improvement over best prior work. Demonstrated in self-powered hydrogen production system, this approach achieves a record gas yield of 16.5 mL/(min·m 2 ), resolving the challenge of low-voltage inefficiency in self-powered systems. Additionally, it is capable of powering a mobile phone. Our work establishes a foundational framework for implementing efficient TENG-powered devices in Internet of Things networks and industrial applications, bridging the gap between energy harvesting technologies and actual energy demands.
Case Report
SEP 24XuFrontiers in Immunology
Gefitinib-based therapy in refractory hepatocellular carcinoma with EGFR overexpression: a spatial profiling-guided case report
Current systemic treatments for advanced hepatocellular carcinoma (HCC) such as antiangiogenic targeted therapies, immune checkpoint inhibitors (ICIs), and their combinations have shown benefit, but widespread drug resistance severely limits patient outcomes and underscores an urgent need for effective post-progression strategies. We herein present a case of a patient with advanced HCC who developed cutaneous, pulmonary, and lymphatic metastases following failure of multiple lines of tyrosine kinase inhibitors (TKIs) including donafenib and regorafenib, and lenvatinib plus anti-programmed death-1 (PD-1) monoclonal antibody (tislelizumab) alongside radiotherapy. Next-generation sequencing (NGS) of the primary liver surgical sample confirmed wild-type EGFR status without canonical driver mutations, whereas retrospective immunohistochemistry (IHC) and cyclic multiplexed tyramide signal amplification (CmTSA) of the cutaneous metastatic sample demonstrated EGFR protein overexpression. Subsequent spatial analysis demonstrated that EGFR-high tumor regions strongly correlated with hyper-proliferative Ki67+ tumor cells. Furthermore, this EGFR-high niche was spatially associated with an immunosuppressive microenvironment characterized by the infiltration of PD-L1+ myeloid cells, CD14+ monocytes, regulatory T cells (Tregs), and PD-L1+/IDO1+ tumor cells. Therefore, we formulated a spatial profiling-guided therapeutic hypothesis and added gefitinib to the prior regimen of lenvatinib plus tislelizumab concurrent with radiotherapy, achieving significant tumor regression despite subsequent intracranial progression. In conclusion, these findings suggest that spatial profiling offers valuable therapeutic insights, highlighting the potential benefit of an EGFR-targeted triplet strategy in refractory HCC with EGFR protein overexpression. While confounding effects from concurrent therapies cannot be excluded, this profiling-guided hypothesis warrants further prospective clinical and mechanistic validation.
Original Research
SEP 26QinLangmuir
Fast Droplet Shedding via Aerodynamic Ratchet on a Moving Surface
The rapid detachment of liquid from engineered surfaces is significant to applications ranging from self-cleaning and energy harvesting to anti-icing. While droplet repellency on stationary surfaces has been extensively achieved through surface chemistry and micro/nanotexture, the impact dynamics of droplets on rapidly moving surfaces remains poorly understood. Here, we systematically investigated the interaction between droplets and a moving surface with a horizontal velocity up to 50 m/s, identifying two distinct bouncing regimes. At low surface velocities, droplets undergo asymmetric bouncing, leading to a modest contact time reduction of approximately 25%. Above a critical surface velocity, however, droplets detach in the pancake configuration, reducing the contact time by approximately 65%. This transition arises from the lubrication pressure generated by an entrained air layer between the droplet and the rapidly moving surface, which suppresses conventional retraction and promotes early lift-off. We develop a scaling law that predicts the critical velocity separating these two regimes, providing a quantitative framework for controlling droplet contact time on moving surfaces. These findings not only advance fundamental understanding of liquid–solid interactions on moving surfaces but also offer practical strategies for minimizing liquid–surface contact in high-speed systems, including ice prevention in aircraft engines and erosion mitigation in turbine blades.
Original Research
SEP 17GuoNano Letters
Iontronic Triboelectric Sensing for Adaptive Robotic Perception before and during Contact
Adaptive robotic manipulation requires sensing systems capable of both anticipating contact and resolving haptic interactions. Existing triboelectric sensors operate through electron transport alone and are intrinsically limited to contact-triggered signal generation, preventing unified tele-perception and haptic perception. Here we introduce an iontronic triboelectric sensor (ITS) that exploits coupled ionic and electronic carrier transport to stabilize triboelectric charge generation while extending electrostatic perception beyond physical contact. Based on a PVDF-ionic liquid-TiO2 composite dielectric with optimized surface microstructuring, the ITS enables haptic pressure sensing over 0–70 kPa in the contact-separation mode and human-target tele-perception up to 1.1 m in the single-electrode mode. The same 1D-CNN is independently applied, achieving 91.3% accuracy for material pre-recognition before contact and 90.28% accuracy for material recognition during contact. Integrated with a robotic hand, the ITS enables closed-loop tele-perception–haptic perception–action feedback for adaptive grasping, providing a self-powered multimodal platform for embodied intelligence and autonomous robotics.
Original Research
SEP 15PanAdvanced Functional Materials
Vectorial Slip‐Touch Perception Enabled by Sliding‐Gated Charge Carrier Dynamics
High‐dimensional tactile perception is essential for dexterous robotic manipulation, but is severely constrained by the hardware‐stacking of pixelated arrays or the computational latency of inverse‐problem algorithms. To overcome these bottlenecks, we report a monolithic, array‐free robotic skin (SG‐skin) driven by sliding‐gated carrier dynamics, achieving high‐fidelity, vectorial slip‐touch perception. Specifically, leveraging a localized triboelectric field acting as a moving gate, the SG‐skin triggers reversible microscopic p ‐to‐ n inversion and directional carrier transport within a continuous semiconductor film, deterministically translating macroscopic mechanical stimuli into vectorial electrical signatures. Supported by an analytical model that validates in‐sensor signal decoupling, a minimalist four‐electrode design augmented by a computationally lightweight machine learning framework concurrently resolves sliding speed, omnidirectional trajectory (1° precision), material type, and touch localization. Ultimately, our SG‐skin maps complex tactile stimuli into deterministic commands, enabling agile human‐machine interaction and advanced closed‐loop robotic control. By breaking the longstanding dependency on complex sensor arrays or resource‐intensive computations, this sliding‐gated strategy translates microscale charge carrier dynamics into macroscopic intelligent perception, providing a scalable and robust material foundation for next‐generation embodied intelligence.
Original Research
SEP 12ZhangAdvanced Energy Materials
Self‐Sustaining Water–Electricity Co‐Supply Via a Wirtz‐Pump‐Driven Triboelectric Nanogenerator
Experimental study demonstrates simultaneous water conveyance and electricity generation using a Wirtz-pump-driven nanogenerator, highlighting scalable off-grid water-energy resilience.
Original Research
SEP 9NanNature Communications
Multi-interface electrical double layers dynamics as a unified platform for power generation and environmental intelligence
Experimental study demonstrates dynamic electrical double layers harness wave power and encode sensory data, indicating a robust strategy for self-powered environmental intelligence.
Original Research
SEP 4ShahThe Journal of Physical Chemistry Letters
Nonaqueous Contact-Electro-Chemistry Enables C–N Coupling
Experimental study reveals contact electrification drives selective C–N coupling in a nonaqueous PTFE–DMSO system, highlighting a new platform for ambient mechanochemical synthesis.
Original Research
AUG 26LiNature Communications
Iontrovoltaic effect based on triboelectrically induced ion polarization at semiconductor-liquid interfaces
Experimental study demonstrates an iontrovoltaic mechanism at semiconductor-liquid interfaces, highlighting opportunities for autonomous, low-power ionic-electronic systems.
Original Research
AUG 25YuFishes
Evaluation of Rice Yield Attributes, Loach Muscle Quality, and Soil Biochemical Composition Under Rice–Loach Coculture System
Controlled trial demonstrates enhanced loach muscle quality and soil biochemical activity under rice–loach coculture without reducing rice yield, indicating a sustainable agricultural strategy.
Original Research
AUG 21DongJournal of the American Chemical Society
Interfacial Water Networks Regulate Solid–Liquid Contact Electrification
Experimental study demonstrates interfacial water structure governs solid–liquid contact electrification, indicating a tunable pathway to enhance energy harvesting and electro-catalysis.
Original Research
AUG 24YangACS Applied Materials & Interfaces
Asymmetric Radiative Cooling Film for Energy-Efficient Thermal Management in Outdoor Low-Temperature Spaces
Mitigating heat stress requires energy-efficient outdoor cooling strategies. Passive daytime radiative cooling (PDRC) has emerged as a promising energy-free cooling strategy, yet its application in outdoor low-temperature spaces remains limited because conventional isotropic designs simultaneously radiate heat to outer space and the protected space. Here, we report an asymmetric radiative cooling film (ARCF) that enables energy-efficient thermal management in outdoor low-temperature spaces through directional thermal radiation regulation. The ARCF employs a bilayer architecture that decouples the radiative functions of two surfaces, combining a polytetrafluoroethylene/silicon dioxide fibrous layer for upward radiative cooling with a low-emissivity aluminum layer for suppressing downward radiative heat transfer. Consequently, the ARCF reduces radiative heat gain into enclosed spaces while maintaining efficient subambient surface cooling. Outdoor experiments demonstrate effective low-temperature preservation, with a maximum chamber temperature difference of 7.2 °C compared with conventional PDRC materials. EnergyPlus simulations further demonstrate substantial cooling energy savings across multiple climate zones. This work establishes an asymmetric radiative strategy for energy-efficient thermal management of outdoor low-temperature applications.
Original Research
AUG 21ZhangScience Advances
Dynamically manipulated interface polarization via symmetry engineering for self-gated electronics
Experimental study demonstrates dynamic interface polarization in bulk centrosymmetric semiconductors, highlighting opportunities for compact self-gated logic and memory devices.
Original Research
AUG 13OdumISPRS International Journal of Geo-Information
A Cloud-Native Python GIS Framework for Flood Susceptibility Screening and Critical Facility Exposure Analysis: A Reproducible Methodological Demonstration for Miami, Florida
Geospatial modeling study demonstrates high flood susceptibility across coastal and canal corridors, indicating substantial potential exposure for critical municipal infrastructure.
Original Research
AUG 12GaoAdvanced Materials
Hydroxylation Regulated Polar Interfaces for Enhanced Contact‐Electro‐Catalysis
Laboratory study reveals enhanced contact-electro-catalysis on hydroxylated tourmaline interfaces, suggesting a viable strategy for mechanically driven environmental catalysis.